Harrier
Six-arm endurance platform with the redundancy to keep observing after a motor fault.
The production CAD, live.
The same OpenSCAD geometry that goes to the printer, exported for the browser. Drag to orbit, or use the controls.
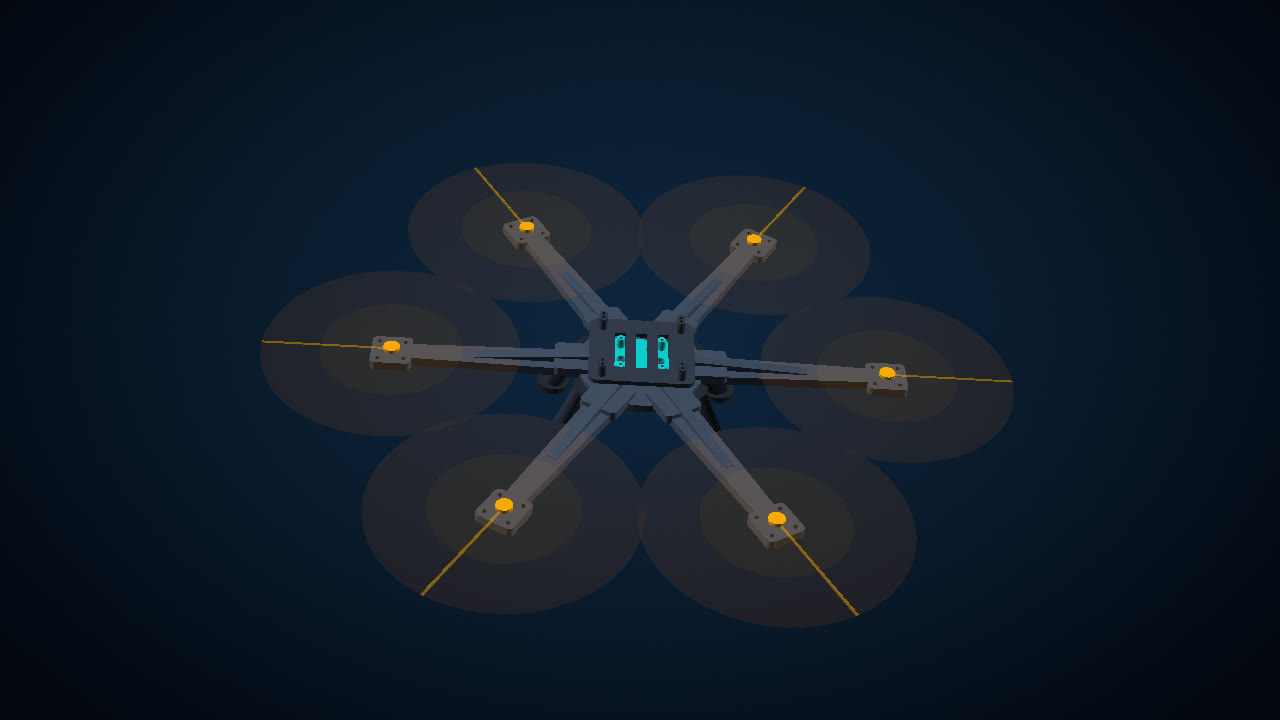
Drag to orbit · arrow keys rotate and tilt · + / − zoom · 0 resets.
The Harrier hexacopter carries the same Pi 5 + Hailo-8L perception stack on a six-arm hub with dovetail-jointed arms, twin trays and long legs for a downward sensor bay. Six motors give it one-motor-out redundancy and a steadier camera platform for longer flight times over a training area.
- Configuration
- Hex X, 6 arms, dovetail joints
- Flight controller
- Pixhawk 6C · ArduPilot Copter 4.6.3
- Perception
- Raspberry Pi 5 + Hailo-8L (13 TOPS)
- Redundancy
- One-motor-out controlled flight
- Airframe
- FDM PLA · multi-part hub / arm × 6 / trays / legs
- Payload
- Sensors only · non-lethal
The rest of the family.
4Quad
The primary detection airframe. Printed, sliced, and on the bed for Test #1.
View platformLongbow 7
Channel-arm 7-inch endurance quad, sized from the knowledge-base stiffness model.
View platformDetection Node
A stationary edge-AI node that shares the drone perception stack for fixed coverage.
View platform